1. Introduction & Overview
What are Companion/Service Robots?
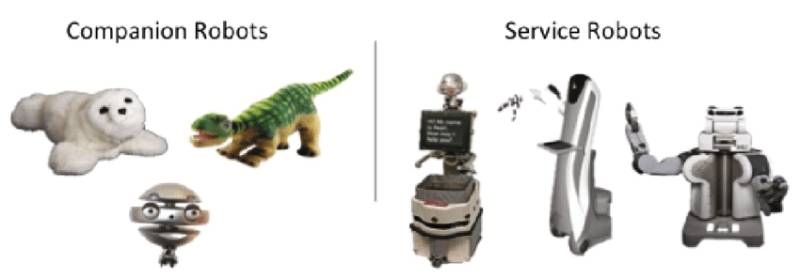
Companion/Service Robots are autonomous or semi-autonomous robots designed to assist humans in daily activities, either at home, in healthcare, retail, or industrial settings. Unlike industrial robots (which focus on manufacturing tasks), companion/service robots interact directly with people, providing social, healthcare, hospitality, and personal support functions.
Examples include:
- Healthcare service robots (assisting elderly patients, medication delivery)
- Retail robots (guiding customers, inventory assistance)
- Household companion robots (vacuum cleaners, elder-care assistants, pet robots)
- Hospital service robots (transporting supplies, disinfecting rooms)
History & Background
- 1960s–1970s: First service robots appeared in hospitals for delivering items.
- 1980s: Companion robots in research labs (e.g., MIT’s Kismet social robot).
- 1990s: Sony introduced AIBO robotic pet.
- 2000s: Widespread household robots like iRobot Roomba gained popularity.
- 2010s: AI-powered service robots such as Softbank’s Pepper began interacting with customers in retail and banking.
- 2020s onwards: Companion/service robots integrated with cloud robotics, IoT, and RobotOps platforms for lifecycle management.
Why is it Relevant in RobotOps?
RobotOps (Robotics Operations) is the DevOps-inspired approach to managing the lifecycle of robots, including:
- Deployment
- Monitoring
- Scaling
- Updating software/firmware
- Ensuring safety and compliance
Companion/service robots require continuous updates, security patches, anomaly detection, and remote monitoring—making RobotOps essential for reliability and trustworthiness.
2. Core Concepts & Terminology
| Term | Definition | Example in Service Robots |
|---|---|---|
| HRI (Human-Robot Interaction) | Methods for communication between humans and robots | Voice recognition in Alexa-enabled robots |
| Telepresence | Remote presence through robots | Hospital telepresence robots for doctors |
| Autonomous Navigation (SLAM) | Robot’s ability to map and move in environments | Hospital robot navigating hallways |
| Edge AI | AI computations on robot hardware | Facial recognition for elderly care robot |
| Fleet Management | Managing multiple robots remotely | Retail chain monitoring all customer service robots |
How it fits into the RobotOps Lifecycle
- Plan: Define service tasks (cleaning, guiding, assisting)
- Build: Develop robot software stack (AI, NLP, navigation)
- Deploy: Rollout firmware/ML models to robots
- Monitor: Track robot health, task success rate, anomalies
- Automate: Enable self-healing, remote updates
- Scale: Expand to multiple robots in different locations
3. Architecture & How It Works
Key Components
- Hardware – Sensors (LIDAR, cameras), actuators, wheels/arms
- Software stack – OS (ROS/ROS2), navigation system, AI models
- Cloud integration – For updates, analytics, and monitoring
- Communication layer – MQTT, WebSockets, or 5G
- RobotOps layer – CI/CD pipelines, monitoring, alerting, logging
Internal Workflow
- User interacts (voice, app, gesture)
- Robot processes command via AI/NLP
- Navigation & path planning module calculates route
- Task executed (e.g., fetch item, answer question)
- Logs sent to RobotOps monitoring system
- Updates/patches deployed remotely via cloud
Architecture Diagram (Textual Description)
 [User]
   │
   ▼
 [Input Interface: Voice/App/Gesture]
   │
   ▼
 [Robot Processing Unit (AI, NLP, SLAM, Sensors)]
   │
   ▼
 [Task Execution: Motors, Actuators, Display]
   │
   ▼
 [Data & Logs] → [RobotOps Layer: CI/CD, Monitoring, Security]
   │
   ▼
 [Cloud & Fleet Management]
Integration Points with CI/CD or Cloud Tools
| RobotOps Tool | Purpose in Companion/Service Robots |
|---|---|
| GitHub Actions / GitLab CI | Automating robot firmware/AI model deployment |
| Kubernetes + ROS2 | Orchestrating multiple service robots in fleets |
| Prometheus + Grafana | Monitoring robot health (battery, CPU, task success) |
| AWS RoboMaker / Azure Robotics | Cloud simulation and fleet management |
| ELK Stack | Logging robot activity for audits |
4. Installation & Getting Started
Prerequisites
- Ubuntu 20.04+ with ROS2 (Robot Operating System) installed
- Docker & Kubernetes (for RobotOps pipeline)
- Cloud account (AWS, Azure, or GCP)
- Basic hardware: LIDAR, camera, microcontroller (Raspberry Pi/Jetson Nano)
Step-by-Step Setup (Beginner-Friendly)
- Install ROS2
sudo apt update && sudo apt install ros-foxy-desktop
- Setup Workspace
mkdir -p ~/robot_ws/src
cd ~/robot_ws/
colcon build
- Run Simulation in Gazebo
ros2 launch turtlebot3_gazebo turtlebot3_world.launch.py
- Integrate with RobotOps CI/CD (GitHub Actions example)
name: Robot Deployment Pipeline
on: [push]
jobs:
  build-deploy:
    runs-on: ubuntu-latest
    steps:
      - uses: actions/checkout@v2
      - name: Build ROS2 package
        run: colcon build
      - name: Deploy to Robot
        run: ssh robot@ip 'docker pull myrobot:latest && docker restart robot-service'
5. Real-World Use Cases
| Industry | Application of Service Robots | RobotOps Role |
|---|---|---|
| Healthcare | Patient monitoring, medication delivery, telepresence doctors | Remote updates, compliance checks |
| Retail | Guiding customers, checking stock, advertising | Fleet orchestration, uptime monitoring |
| Hospitality | Concierge robots, room service delivery | Logging, anomaly detection |
| Home Assistance | Elderly care, cleaning, companionship | Security updates, privacy monitoring |
6. Benefits & Limitations
Benefits
- Improves efficiency in healthcare/retail
- Provides companionship to elderly/disabled
- Reduces human workload
- Enables 24/7 operation
- Can be remotely monitored and updated via RobotOps
Limitations
- High initial cost of deployment
- Privacy & data security concerns
- Dependency on internet/cloud
- Ethical & emotional considerations in companionship
- Maintenance and hardware wear-out
7. Best Practices & Recommendations
- Security: Encrypt robot-cloud communication (TLS, VPN)
- Performance: Use edge computing for faster response times
- Maintenance: Schedule OTA (over-the-air) updates via CI/CD
- Compliance: Follow GDPR/HIPAA for healthcare robots
- Automation: Implement self-healing scripts for error recovery
8. Comparison with Alternatives
| Category | Service Robots | Industrial Robots | Telepresence Robots |
|---|---|---|---|
| Purpose | Assist/companion to humans | Manufacturing & production | Remote communication |
| Interaction | High (voice, social) | Low (machine-oriented) | Medium (remote user control) |
| RobotOps Needs | Continuous updates, monitoring | Process automation | Network reliability |
| Example | Pepper, Roomba, AIBO | KUKA, ABB | Double Robotics |
9. Conclusion
Companion/Service Robots are becoming an integral part of healthcare, retail, and households. With the rise of RobotOps practices, managing these robots at scale has become secure, automated, and cloud-integrated.
Future Trends
- AI-driven emotional intelligence in robots
- Integration with 5G & edge computing
- Cross-industry standardization for RobotOps in service robots
- Cloud-based fleet management with self-healing robots
Next Steps:
- Explore ROS2 with AWS RoboMaker for real deployment
- Join communities like ROS Discourse and Open Robotics
- Experiment with RobotOps CI/CD pipelines to automate deployments
